Drone Controller
The Pixhawk ArduPilot Drone Controller project is an innovative Internet of Things (IoT) solution designed to create an intelligent, autonomous drone system. Leveraging the Pixhawk flight controller and ArduPilot…
About Project
The Pixhawk ArduPilot Drone Controller project is an innovative Internet of Things (IoT) solution designed to create an intelligent, autonomous drone system. Leveraging the Pixhawk flight controller and ArduPilot software, this project provides cutting-edge features for drone control, automation, and mission planning.
Our Task was
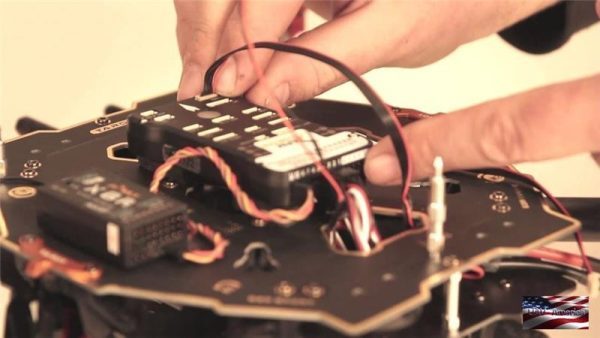
Identifying and sourcing the necessary hardware, such as the Pixhawk flight controller, GPS module, ESCs (Electronic Speed Controllers), motors, and other drone components. Configuring the Pixhawk flight controller to run the ArduPilot software, which provides the drone’s flight modes, such as manual, automatic, guided, and RTL (Return to Launch).Building an intuitive user interface (UI) to control the drone remotely, including features for manual flight control, mission planning, and data collection.
Process
The CellCheck Modular Battery Management System is an advanced solution designed for real-time battery monitoring and safety. This project focuses on developing and integrating cutting-edge features like Battery Safety AI, edge analytics, and secure data communication for KULR Technology Group.
- Research & Component Selection
- Integration of Hardware and Software
- Control System Development
- Mission Planning
- Testing and Validation
- Iterative Improvements
Result
- The drone can fly autonomously by following a pre-programmed route or waypoints, ensuring it can perform repetitive tasks like surveying, inspections, and monitoring.
- The drone collects real-time data, such as GPS coordinates, altitude, and sensor readings, which are transmitted back to the ground control station for analysis.
- The user interface allows easy manual control of the drone and real-time monitoring of its status, ensuring smooth operation.
- The drone has undergone rigorous testing to ensure that it operates reliably even in challenging conditions, including wind, varying altitudes, and long-distance communication.
Conclusion
The Pixhawk ArduPilot Drone Controller project successfully achieved the goal of developing a fully functional, autonomous drone that can be controlled remotely and can execute missions with minimal human input. This project demonstrates the power and potential of combining Pixhawk hardware with the ArduPilot open-source software, providing a versatile platform for various applications in industries such as agriculture, surveying, delivery services, and environmental monitoring.
Have a similar project in mind?
Tell us what you're working on. Our engineers will review it and get back to you.